
About the project
Objective
This project aims to develop a theoretically grounded, data-driven congestion control framework that combines output regulation, online feedback optimization, and reinforcement learning to achieve autonomous and optimal congestion mitigation in power grids, with guaranteed robustness and adaptability to renewable generation uncertainties, without relying on explicit grid models.
Background
The electrical power grid is undergoing a profound transformation driven by digitalization, market deregulation, and the rapid integration of renewable and flexible energy resources. The EU Green Deal and Sweden Climate Policy Framework set ambitious targets for a sustainable and resilient energy system, while addressing energy poverty. Yet, unlike traditional centralized plants, renewables are dispersed and weather-dependent, pushing the grid close to its operational limits. When congestion occurs, overloaded lines threaten stability and clean energy is curtailed. Industry manual and semi-automated congestion management mechanisms cannot cope with this growing complexity. The recent large-scale blackout across the Iberian Peninsula has revealed the fragility of existing operational paradigms and the urgent need for the integration of more efficient autonomous, data-driven control. This raises a fundamental question: How can we design autonomous, data-driven congestion control algorithms that harness the increased digitalization of the power grid to ensure efficient and reliable operation despite the volatility of renewable generation? To address this question, this project aims to develop a robust online reinforcement learning framework, grounded in output regulation theory and online feedback optimization, that learns optimal congestion mitigation strategies directly from real-time power grid data without relying on an explicit grid model.
About the Digital Futures Postdoc Fellow
Liquan Lin received his PhD from The Chinese University of Hong Kong, where his research focused on developing data-driven control methods for uncertain linear systems, with particular emphasis on the output regulation problem. His current research interests lie at the intersection of output regulation theory and feedback optimization, with a focus on data-driven methods and their applications to power systems.
Main supervisor
Giuseppe Belgioiso
Co-supervisor
Qianwen Xu
About the project
Objective
This project argues that urban autonomous systems should be understood as publicly sustained rather than self-sufficient. It aims to conceptualise the invisible public work through which this dependency is maintained and to explore how design can make it more legible and socially sustainable.
Background
Urban digitalisation is bringing autonomous technologies into urban public space, from service robots on sidewalks to autonomous mobility services and intelligent urban infrastructure. These systems are often framed and deployed as self-sufficient forms of machine autonomy. Yet in practice, their everyday operation frequently depends on co-present people who interpret their behaviour, adapt their own actions, and at times intervene to resolve issues. This is exemplified by pedestrians altering their paths to grant robots passage and removing obstacles or providing instructions when robots become immobilised, and by drivers adjusting their behaviour to ensure safe interaction with autonomous vehicles. This suggests that what appears as machine autonomy is often sustained through invisible public work.
However, this dependency remains under-recognised in both design and deployment. As a result, the work required from the public is often left to emerge informally, without being made legible or supported through design. This can place unfair burdens on people and create friction in shared spaces, undermining public trust and acceptance of these technologies. To address this gap, the project aims to propose and develop the concept of publicly sustained autonomy through empirical and design research. This concept reframes urban autonomous systems as sociotechnical arrangements whose operation depends not only on technical autonomy, but also on distributed support from the public. Building on this framing, the project investigates how urban autonomous systems can be designed to make the public work that sustains them more legible and socially sustainable, and under what institutional conditions such approaches can be deployed responsibly in public space.
About the Digital Futures Postdoc Fellow
Xinyan Yu is a Design and Human–Computer Interaction researcher. She received her PhD from the Design Lab at the University of Sydney. Her research examines how emerging autonomous technologies become part of everyd
ay public life, with a particular focus on human interactions with service robots and autonomous vehicles in urban environments. Situated at the intersection of design research, human-computer interaction, and human robot interaction, her work investigates how these systems are encountered and experienced in everyday settings, and how design can support their integration in more socially meaningful ways.
Main supervisor
Andrii Matviienko, KTH Royal Institute of Technology.
Co-supervisor
Airi Lampinen, Stockholm University
About the project
Objective
The project aims to identify and validate the mechanisms that enable successful and long-term industry–academia collaboration within the Digitalized Industry Working Group. By collecting and analysing collaboration experiences from researchers and industrial partners, the project will develop a practical playbook that supports future collaborative research, innovation activities, and proposal development across Digital Futures.
Background
The Digitalized Industry Working Group brings together researchers from multiple disciplines who collaborate with a wide range of industrial partners. While these collaborations generate valuable experience, knowledge is often distributed across individual projects and organisations. This project addresses that challenge by systematically capturing collaboration experiences through structured surveys and comparative analysis. The resulting playbook will help transform accumulated experience into practical guidance for future industry–academia collaboration within Digital Futures.
Cross-disciplinary collaboration
The project combines expertise from production engineering, cyber-physical systems, energy systems, digital twins, living labs, and industrial innovation. The project team spans four complementary disciplines within the Digitalized Industry Working Group and collaborates with industrial partners. This cross-disciplinary approach enables the project to compare collaboration models across different industrial sectors and research domains, creating broadly applicable guidance for future Digital Futures initiatives.
PIs:
- Yongkuk Jeong, Assistant Professor, Department of Production Engineering, KTH
- Martin Törngren, Professor, Department of Engineering Design, KTH
- Marco Molinari, Senior Researcher, Department of Energy Technology, KTH
- Ellen Bergseth, Associate Professor, Department of Engineering Design, KTH
About the project
Objective
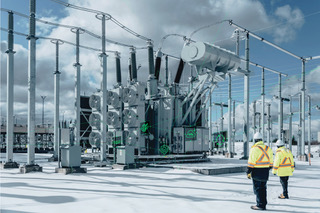
The purpose of the project is to enable an end-user to make practical and useful conclusions about water content in a high-voltage transformers from indirect measurements provided by sensor data, including an understanding of the water content in the paper insulation and moisture in oil. To do so an advanced digital twin model will be developed that includes the simulation of non-uniform water distribution and allows for interpreting measurements from sensors. This will enable accurate life-cycle assessment.
Background
Electric insulation is an important part of stable and safe operation of high-voltage components and plays a key role in power delivery and meeting future rising electricity demand. One important component of this is the moisture dynamics in the transformer insulation. Moisture affects aging, reliability, and can lead to dielectric breakdown and subsequent component failure. Hence, it plays a crucial role in power generation and distribution. Insight into how water residual is distributed inside the transformer insulation is crucial for evaluating its safety, aging and overall reliability.
This project uses mathematical insight to build a digital twin that reliably and continually updates the moisture model based on real-time data. This will allow insight into information about various processes related to the moisture dynamics that are challenging to obtain otherwise and lays the foundation for real-time monitoring systems and accurate life-cycle assessment of key assets, which contributes to building a smart society.
Crossdisciplinary collaboration
The project is a collaboration between KTH, Hitachi and Imperial College.
Principal Investigators (PIs)
- Jennifer K. Ryan, KTH
- Tor Laneryd, Hitachi Energy
- Kateryna Morozovska, Imperial College London
About the project
Objective
Modern autonomous systems are required to operate in close collaboration with human operators in complex, dynamic environments, such as industrial settings, maritime operations, and disaster-response scenarios. In these contexts, autonomy must remain safe, adaptive, and responsive to human inputs, environmental disturbances, and evolving task specifications in real time.
The project aims to develop a unified control framework that enables autonomous systems to safely and adaptively collaborate with humans in complex and unstructured environments. Specifically, it will bridge high-level task allocation and trajectory planning with low-level feedback control using the mathematical paradigm of hybrid systems, and it will enable interactive decision-making and human supervisory inputs through the integration of game theoretic principles.
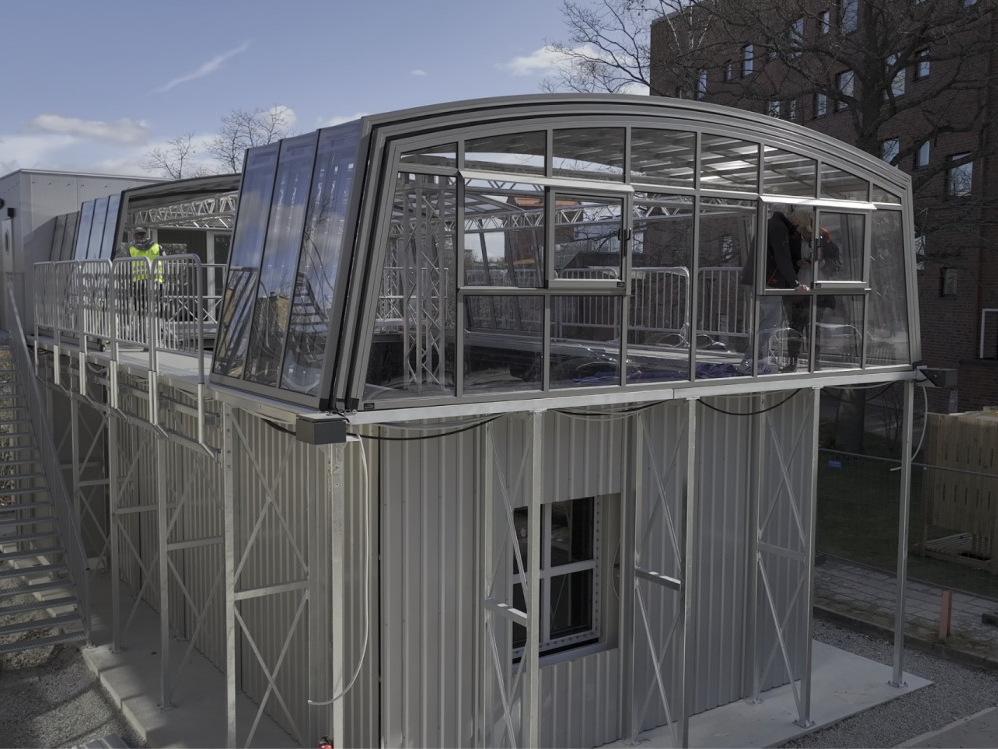
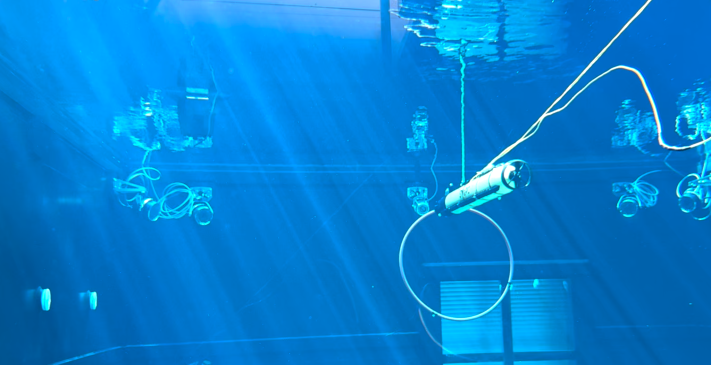
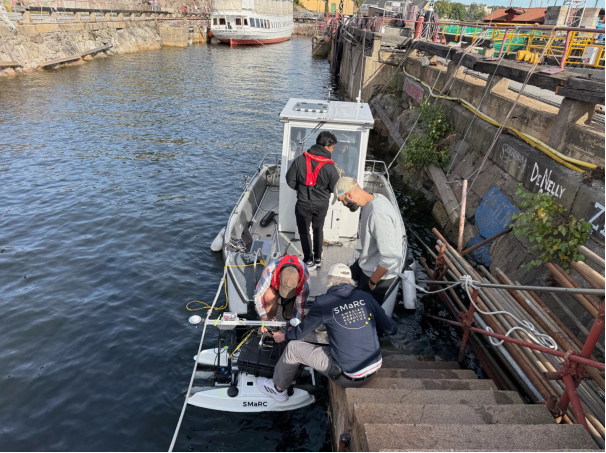
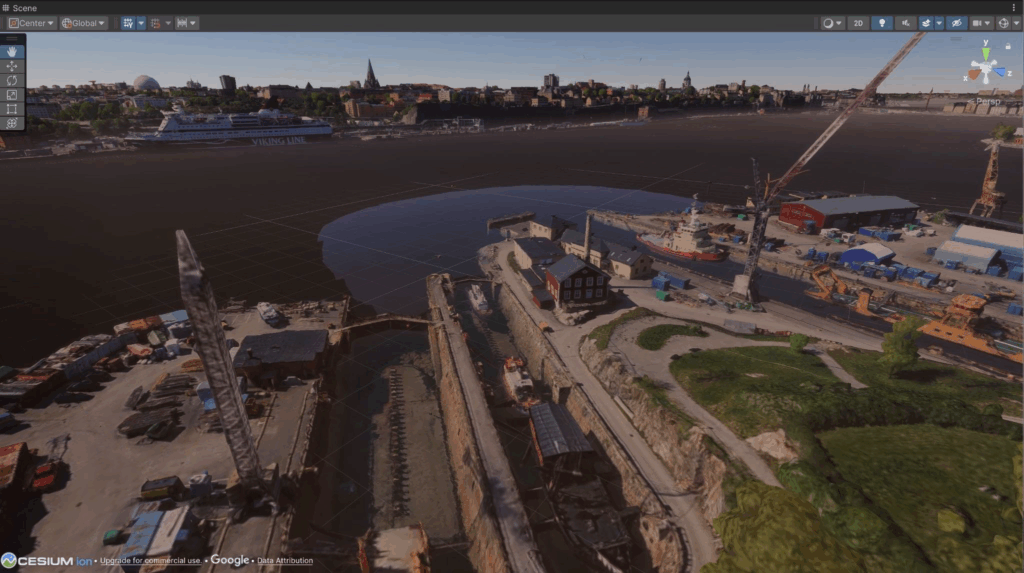
The project will further translate this theoretical framework into computationally tractable controllers suitable for real-time implementation on mobile autonomous systems. The proposed approach will be validated through real-world experiments in maritime robotics scenarios, including diver–robot collaboration missions in both controlled test tanks and open-water environments. By integrating new theory and experimental deployment, the project seeks to enable trustworthy, resilient, and adaptive human-in-the-loop autonomy across multiple time scales, from high-level decision-making to low-level feedback control.
Background
In recent years, autonomous systems have been increasingly deployed to work alongside human operators in executing complex, coordinated tasks. Prominent examples include warehouse automation, assembly-line operations, and intelligent logistics, where systems must handle tasks such as sorting, inspection, or replenishment under strict spatial constraints (e.g., limited workspaces and predefined pathways) and temporal requirements (e.g., synchronization and time-critical deliveries).
These challenges become even more pronounced in extreme environments, including underwater robotics, space exploration, and disaster-response scenarios, where systems operate in unstructured and uncertain conditions characterized by limited communication, poor visibility, and strong environmental disturbances. Across both industrial and extreme domains, the ability to adapt task allocation, planning, and control in real time is essential to ensure efficiency, resilience, and safety in human–robot collaboration.
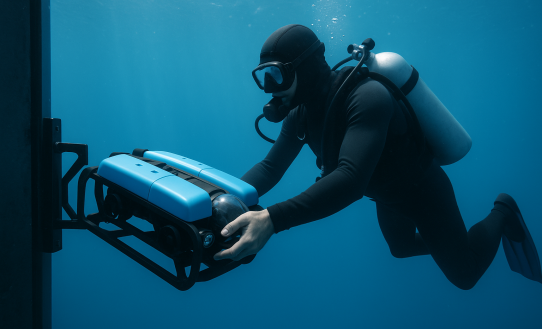
Autonomous systems are increasingly employed alongside humans to perform complex tasks in both structured and unstructured environments.
The state-of-the-art control architecture for autonomous systems typically follows a layered structure consisting of task allocation, trajectory planning, and real-time low-level feedback control. Task allocation determines how tasks are distributed among agents, planning generates trajectories that satisfy spatial and temporal specifications, and low-level control ensures accurate tracking and safety. While effective in structured settings, this hierarchical stack is not inherently designed to account for real-time human intervention, changing objectives, or unexpected obstacles, which are central features of human-in-the-loop scenarios.
Cross-disciplinary collaboration
The project brings together complementary expertise in applied mathematics (hybrid systems, formal methods, and game theory), control engineering (model predictive control), and maritime and underwater robotics to address the challenges of human-in-the-loop autonomous systems in extreme environments. This cross-disciplinary collaboration tightly integrates mathematical modelling, control design, and real-world robotic experimentation.
PIs: Giuseppe Belgioioso, Dimos Dimarogonas, and Ivan Stenius.
About the project
Objective
This project aims to provide mitigation solutions for decision-makers to reduce human and environmental exposure to particle emissions caused by the transport sector. Through the use of cross-disciplinary approaches, the project develops methodologies that are tested and validated by adopting Stockholm as a digital sandbox.
Background
In our daily city life, we are constantly exposed to means of transport such as passenger vehicles, heavy-duty vehicles, and rail transportation. These vehicles release toxic particle emissions originating from exhaust and non-exhaust sources. Recent projections indicate an increase of non-exhaust emissions in urban areas from 0.5% in 2021 to 67% in 2050. Non-exhaust emissions are the primary source of inhalable Particulate Matter (PM). With a diameter smaller than 10 µm, PM10 can be inhalable by humans causing inflammations and other health diseases. On the other hand, PM with a size larger than PM10 can deposit over the nearby infrastructures contributing to environmental pollution.
Stockholm is among the forefront European cities capable of monitoring in real-time level of PM and policy makers strive to mitigate these emissions. However, despite these efforts, the concerns regarding the increase of non-exhaust PM in the urban areas remain critical.
About the Digital Futures Postdoc Fellow
Henri Giudici completed his Ph.D. in Civil and Environmental Engineering at the Norwegian University of Science and Technology – NTNU (Norway). He specialized in vehicle tire-pavement interactions in winter conditions. His research supported the Norwegian road authority in reducing road salt application rates during winter. Between 2019 and 2022, he served as an industrial Principal Scientist, developing technologies and data-driven approaches for assessing the quality of transport infrastructures. In 2022, he continued his academic career as a researcher in systems engineering at the University of South-Eastern Norway – USN (Norway). In his current Digital Futures postdoc, Henri fosters agile approaches to integrate scientific evidence into policy-making by bridging transport tribology, systems engineering and data science.
Main supervisor
Ellen Bergseth, Associate Professor at Department of Engineering Design, KTH.
Co-supervisor
Ulf Olofsson, Professor at Department of Engineering Design, KTH.
About the project
Objective
To develop DeepAqua-II, a robust, scalable deep-learning system for global surface-water monitoring using SAR time-series data.
Specific objectives (O1–O5):
- O1: Design a technique to normalize SAR pixel intensity values so models remain resilient to sensor adjustments.
- O2: Build a self-supervised semantic segmentation model using SAR time-series without needing optical data.
- O3: Add support for L-band SAR sensors to detect water under vegetation.
- O4: Quantify changes in surface-water extent across multiple climate regions for 2015–2027.
- O5: Communicate and disseminate results to maximize impact, including training and capacity building.
Background
Surface water is declining worldwide, requiring more accurate monitoring.
- Traditional monitoring depends on optical satellite imagery, which fails under clouds and vegetation.
- Existing SAR-based models require manual annotations and retraining whenever sensors change.
- The earlier DeepAqua project achieved strong performance but still depends on optical data and lacks resilience to sensor adjustments.
- The upcoming NISAR mission introduces L-band SAR, enabling deeper vegetation penetration.
- There is a global need for automated, scalable, optical-independent methods for long-term water-extent mapping.
Crossdisciplinary collaboration
Hydrology & Environmental Sciences
- Led by Professor Zahra Kalantari
- Expertise in water resources management, hydrology, climate-change impacts, and sustainability.
Computer Science & Machine Learning
- Led by Associate Professor Amir H. Payberah
- Expertise in scalable machine learning, deep learning, and time-series modeling.
Nature of collaboration
- Integrates SAR remote sensing, deep learning, and climate/land-water systems.
- Builds on joint results from DeepWetlands and DeepAqua.
- Enables a cooperative system for global-scale water monitoring.