
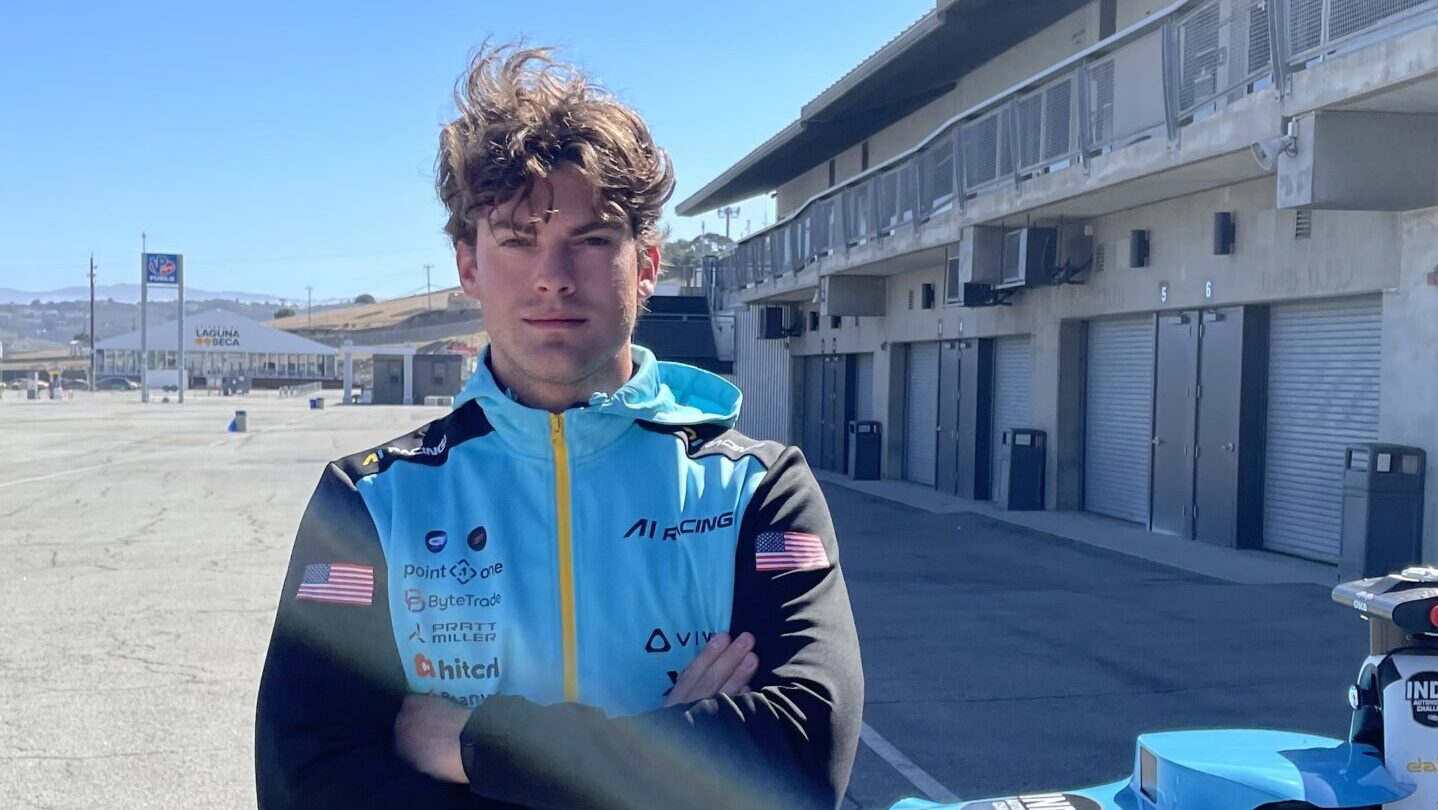
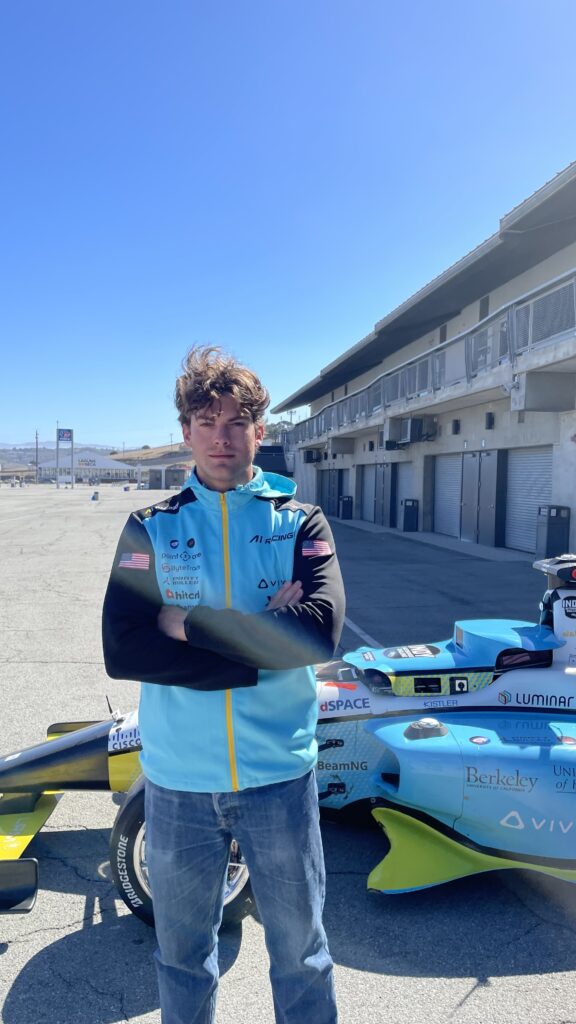
This summer, KTH student Filippo Di Fiore has gained first-hand experience of cutting-edge autonomous racing at UC Berkeley. As part of the AI Racing Tech team, he has been working on the control system of an autonomous Indy race car – with the ultimate test coming at Laguna Seca on 3 September.
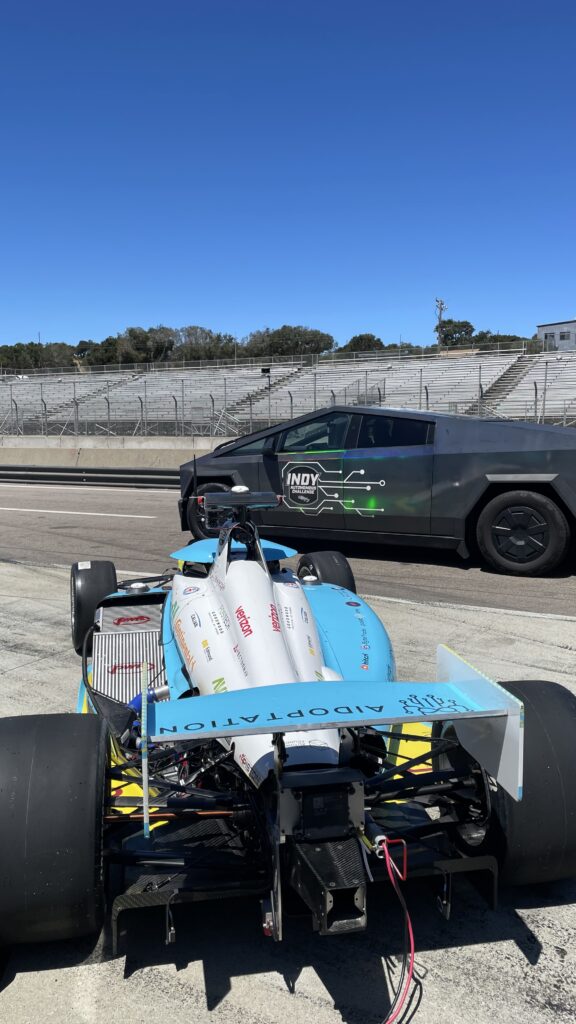
What happens when you combine a high-performance race car, artificial intelligence and students from some of the world’s leading universities? The answer can be seen in the Indy Autonomous Challenge (IAC) 2026, where university teams develop the technology that allows race cars to drive autonomously at extreme speeds.
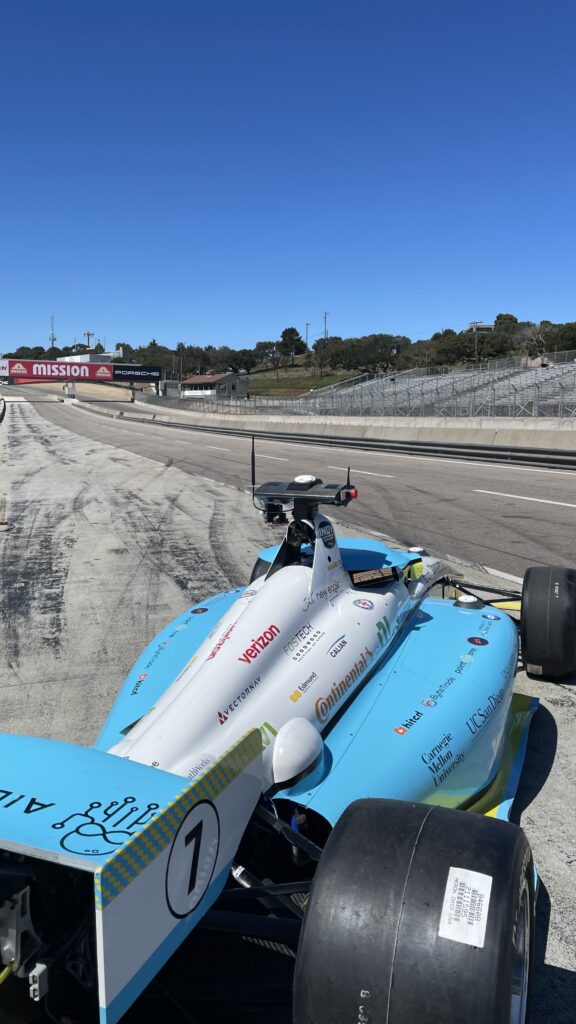
For Filippo Di Fiore, a KTH student spending the summer at the University of California, Berkeley, as part of a Digital Futures-funded Summer Research Internship, the challenge has provided an opportunity to work directly with this technology. Filippo is part of AI Racing Tech, a university team competing in the Indy Autonomous Challenge. The team brings together students and researchers from UC Berkeley, UC San Diego, Carnegie Mellon University and the University of Hawaii.
At KTH, Filippo is also involved with KTH Formula Student, working in the State Estimation team. His summer at Berkeley has given him the opportunity to apply and deepen his knowledge in a very different environment – working on a full-size autonomous race car and as part of a team developing technology at the forefront of autonomous driving.
From algorithms to the racetrack
This summer, Filippo has worked in the control sub-team, focusing on the team’s Model Predictive Control (MPC) framework.
“In simple terms, while a basic controller just tries to stick to a fixed line, a progress-maximisation MPC looks ahead into the future and continuously figures out the fastest way to progress down the track while respecting the vehicle’s physical limits,” he explains.
His work has included reviewing the existing formulation, developing ideas to make it more robust, improving lap times and extensively testing the system in high-fidelity simulation before running it on the actual car.
Autonomous racing is about much more than making a car drive around a track. At racing speeds, the vehicle needs to understand where it is, predict how it will behave, select the right trajectory and react to changing conditions – all while operating within very tight safety and performance margins. The Berkeley ROAR (Robotics and Autonomous Racing) programme, which is part of the FHL Vive Center for Enhanced Reality at UC Berkeley, focuses on autonomous systems, intelligent machines and human-in-the-loop control for extreme robotics applications. Its AI Racing Tech team competes internationally in the Indy Autonomous Challenge.
For students, this creates an unusually hands-on environment in which concepts from robotics, control, machine learning and vehicle dynamics have to work together in the real world. And the stakes are high.
“The seriousness of every single decision you make in the software and control logic” is what has surprised Filippo most about working with a full-size autonomous race car.
At the speeds involved, there is little room for error.
“On smaller robots, a small timing bug or a minor tuning error might just cause a small glitch. On a full-size race car, even a tiny oversight in the controller can instantly cause severe damage to the car,” he says. The experience has changed the way he approaches engineering. “Every single line of code directly decides whether a real car stays on track or crashes,” he says.
The next challenge: Laguna Seca
On 3 September, the Indy Autonomous Challenge returns to WeatherTech Raceway Laguna Seca near Monterey, California, as part of the Grand Prix of Monterey weekend. This year’s competition raises the bar compared with last year’s event. Instead of simply competing for the fastest lap, the autonomous race cars will take part in a head-to-head passing competition – requiring the AI drivers to anticipate another vehicle, defend their position and execute overtaking manoeuvres on a demanding road course.
Laguna Seca is famous for its technical layout, rapid elevation changes and the iconic Corkscrew – a section of track with a dramatic drop that presents a particular challenge for both human and autonomous drivers. For the control team, the track presents a range of technical challenges.
“Laguna Seca is notorious for its steep elevation drops, especially around the Corkscrew, which caused our car to spin out many times in simulation until we properly calibrated the controller parameters,” Filippo says.
The introduction of head-to-head racing adds another layer of complexity. While the MPC aims to maximise progress around the track, it must also respond almost instantly to planner updates during overtaking and defending, while staying within dynamically assigned safe corridors. The team has also worked on accurate tyre modelling, allowing the MPC to estimate available friction at the wheels and determine how hard the car can be pushed without losing grip. Other challenges include compensating for sensor and actuator delays, balancing aggression and stability, and addressing issues such as throttle hunting at cruising speeds.
The challenges extend beyond the control system. Across the autonomous driving stack, the team has had to tackle issues including GPS and RTK (Real-Time Kinematic – a high-precision satellite positioning technology) dropouts in blind spots under bridges and maintaining consistent, real-time tracking of other cars.
For Filippo, the race will be the culmination of a summer spent learning, testing and contributing to a highly interdisciplinary team.
Bringing the experience back to KTH
The experience has also provided Filippo with new perspectives on both engineering and teamwork.
“Technically, I learned a huge amount about high-performance control, the interactions between all the different modules in an autonomous stack, and how to quickly trace track-side bugs back to their root cause under time pressure,” he says.
One of his most important lessons has been the value of getting the fundamentals right before moving into implementation.
“I learned the importance of being meticulous with every single detail and investing the time to get the mathematical formulation right before writing code, rather than relying on quick trial-and-error fixes.”
He has also seen how important communication is when many different teams and systems have to work together.
“When people don’t coordinate closely, you end up with overlapping work and messy module interfaces; keeping everyone aligned on clean interfaces makes the entire team move much faster,” he says.
For Filippo, the summer has been about more than technical skills.
“It gave me the chance to experience a different mindset and work culture, take in new perspectives, and bring those positive habits back with me to Europe,” he says. “I also met great people from all over the world and made lasting friendships.”
His advice to other KTH students is clear: take the opportunity to go abroad.
“I would definitely recommend an international research stay to any KTH student. It really pushes you out of your comfort zone, broadens your horizons, and gives you a much clearer vision of what you want to build moving forward.”
For now, though, there is one immediate goal: getting the AI Racing Tech car ready for Laguna Seca. On 3 September, Filippo will see the result of a summer spent turning algorithms and mathematical models into decisions made at racing speed – on one of the world’s most challenging tracks.